soft-actuator-recalibration
Simulation study of whether pressure-volume loop shape can tell a soft gripper when to recalibrate. At matched cost, a cycle counter does just as well.
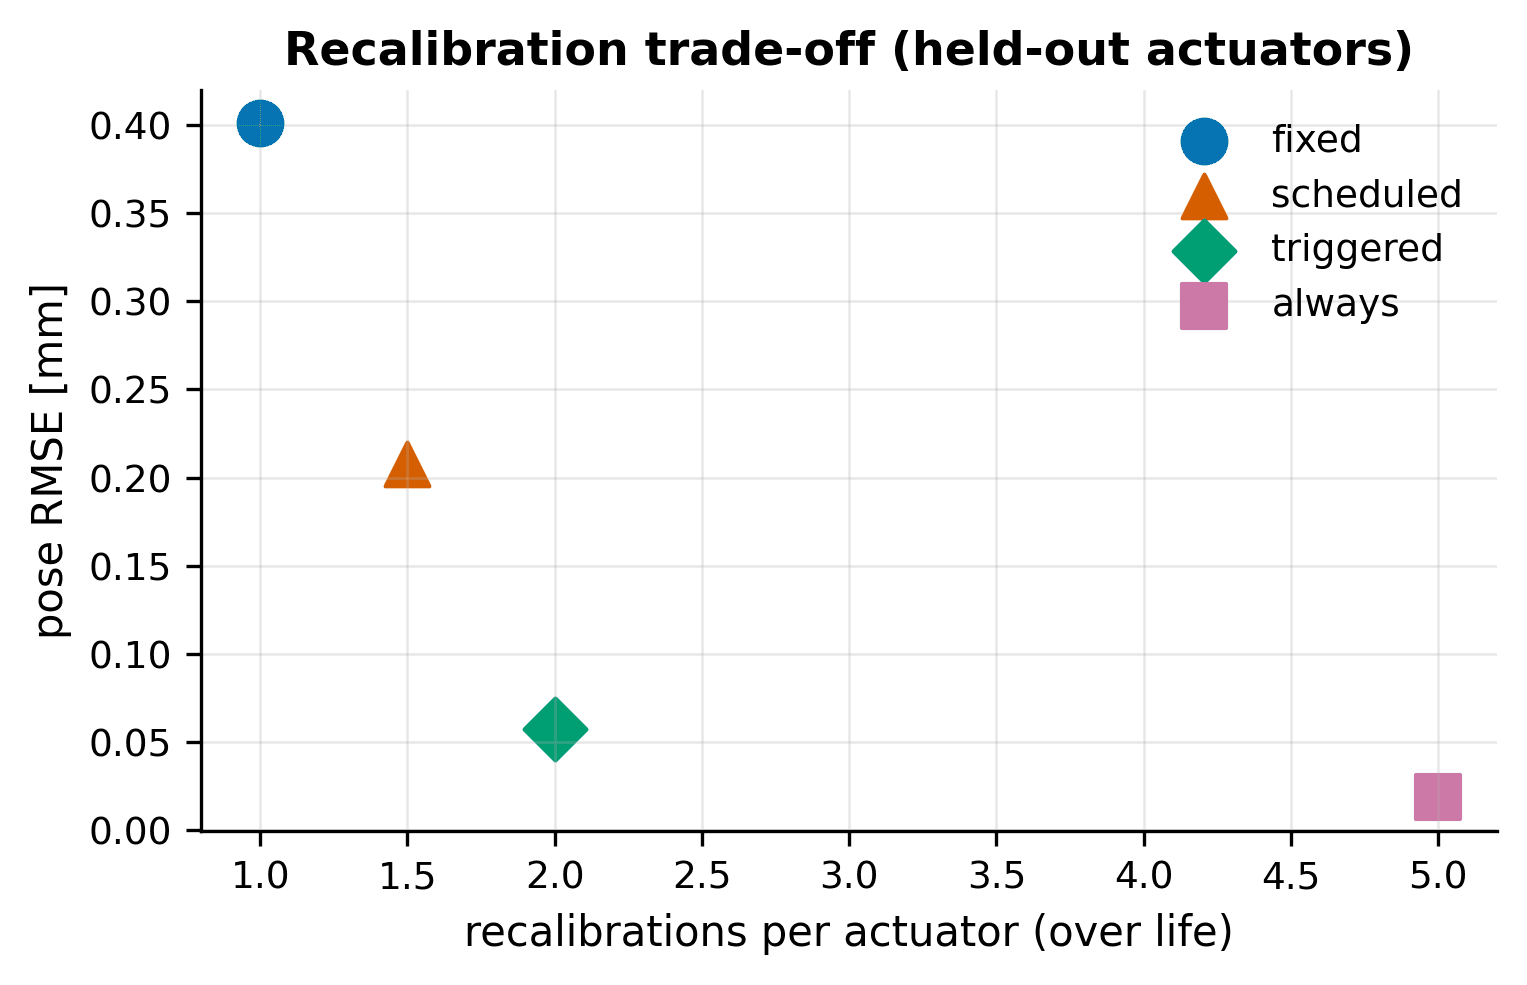
Result. At matched recalibration cost, a cycle-count clock gave the same schedule and pose error as the P-V trigger on all 20 simulated actuators, so the v1.4 preprint was withdrawn rather than released.
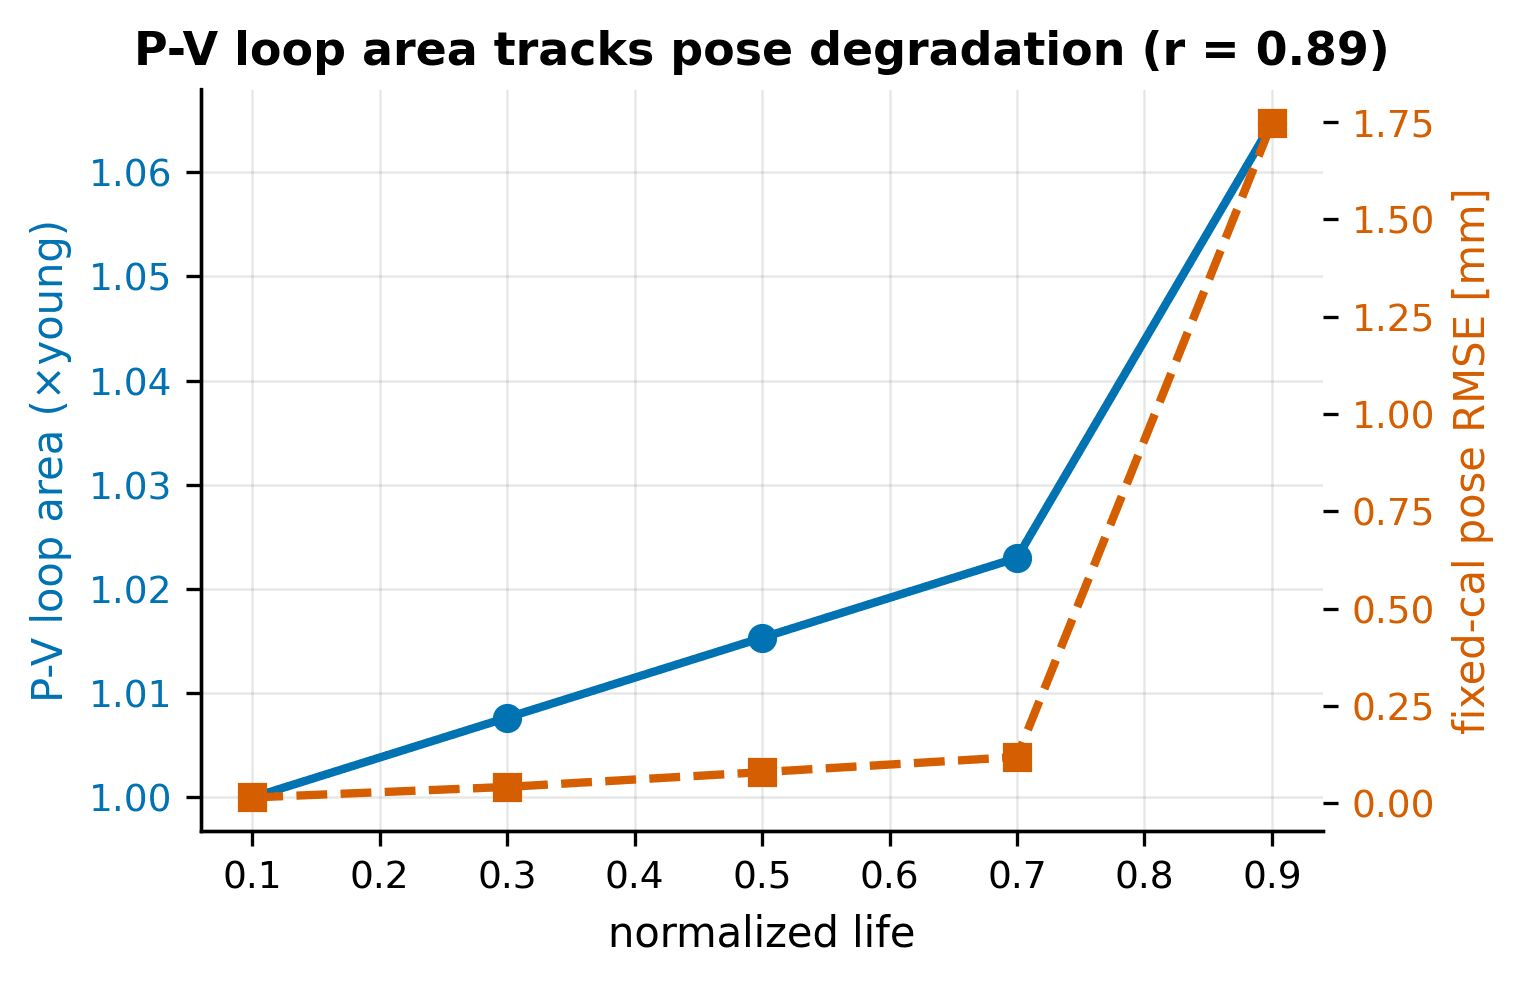
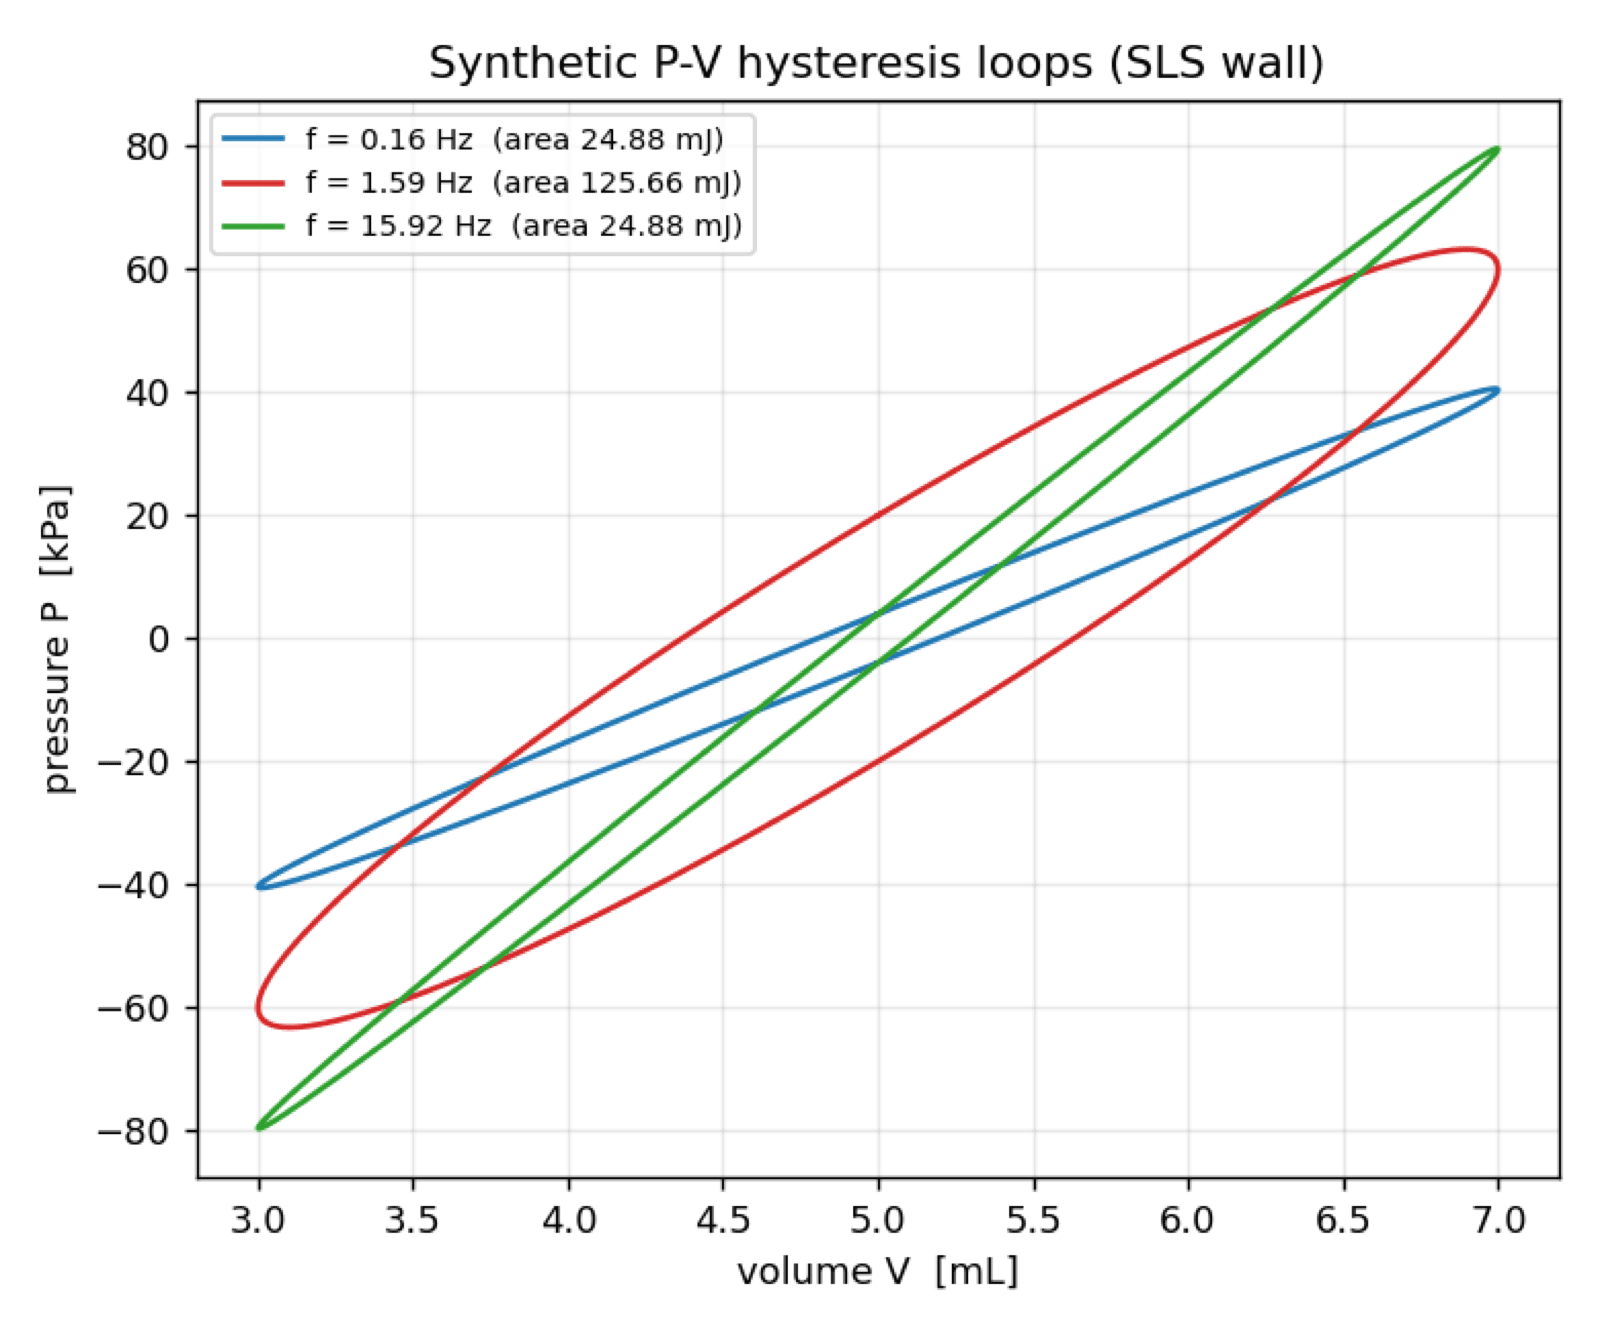
This research asks whether a signal already present in pneumatic control—the pressure-volume hysteresis loop—can track fatigue-driven drift and trigger pressure-only proprioception recalibration in a shared-manifold soft gripper. A later observability program tested whether that signal survives unit-to-unit variation, and found the places where it does not. A final audit before release found that, in this simulator, the signal adds nothing over counting cycles.
| Category | Research |
|---|---|
| Timeline | Jun. 2026 - Jul. 2026 |
| Status | Complete |
| Evidence | Actuator-split simulation |
| Role | Research framing, modeling, preregistered evaluation, statistical audit, manuscript, and reproducibility package |
| Tools | Python, NumPy, SciPy, Matplotlib |
| Links | RepositoryArchived v1.3v1.4 WithdrawalMethods Correction |
problem
My contribution. Built the generative model, actuator-identity split, health-indicator and recalibration evaluation, audit checks, figures, and manuscript/release package.
Soft pneumatic grippers age, while pressure-only pose estimators drift with compliance. A useful health indicator must generalize across actuators and must be audited against a simple clock baseline and an explicit temporal-lead definition.
constraints
- Split train and test data by actuator identity rather than by trace.
- Keep every claim simulation-only until matched hardware evidence exists.
- Report negative or threshold-dependent findings without moving the selection rule.
- Make manuscript numbers machine-checkable against committed JSON results.
design evolution
Iterations, issues, and fixes, recorded in the order they happened.
| Revision | Failure mode | Design change | Result |
|---|---|---|---|
| Mechanism model | A plausible shared-manifold effect could be asserted without separating it from global fatigue drift. | Built isolated-versus-shared supply simulations and actuator-level held-out splits. | Cross-talk exists but is second-order at the registered parameters. |
| Lead-time audit | The selected trigger met the error budget but did not provide warning before violation. | Reported a threshold frontier instead of relabeling the deployed threshold. | Median lead is -0.123 normalized life at the deployed threshold; lower thresholds can buy lead at a recalibration cost. |
| Matched-cost audit | The clock baseline was picked by a fewest-recalibrations rule, so it ran cheaper than the trigger and lost on accuracy. | Reran the comparison at a matched recalibration count with the study's own functions. | A clock every 2,400 cycles gives the trigger's exact schedule and error on all 20 actuators. The health signal equals the simulator's compliance multiplier to within 2e-14, so its r = 0.885 (actuator-cluster CI 0.853-0.950) holds by construction. |
| Methods correction | The Study 3 trigger read a noise-free loop area generated by the same fatigue model as the drift it predicts. | Filed a correction to archived v1.3 and drafted a v1.4 candidate with unchanged numbers and narrowed claims. | The v1.3 correction stands; the v1.4 candidate it led to was later withdrawn by the matched-cost audit. |
results
The full suite validates the pneumatic plant, fatigue model, health features, shared-manifold network, actuator-level evaluation, and manuscript-number traceability.
The decisive check came last: at matched recalibration cost a cycle-count clock ties the trigger exactly, so the trigger's savings against always-on recalibration are not evidence for P-V sensing. At the deployed threshold it also gives no positive warning time.
A follow-up observability program pushed on the same signal and reported three limits: unit-to-unit dispersion breaks its invariance in value, post-onset life estimates are not precise enough to report (the earlier resolution figures were withdrawn), and one transferred estimator misses its preregistered bar on short-lived units.
Scope note. All actuators are generated by one simulation family. No physical fatigue, P-V, or proprioception validation is claimed. Archived v1.3 carries a methods correction, and the v1.4 candidate was withdrawn on 2026-10-02.
lessons
- A health indicator and a leading indicator are different claims.
- Actuator-identity splits are essential when traces from one specimen are correlated.
- Compare against the simple baseline at matched cost; a cheaper baseline that misses the budget proves nothing about the sensor.
gallery