autonomous-racing-systems
Simulator-based vehicle identification, controller comparison, and a LiDAR mast redesign with unresolved vibration clearance.
Result. Modal FEA predicts 285.5 Hz for the analyzed mast. Motor shaft order crosses that mode near 8.3 m/s, prompting a review of whether the raised mount is needed.
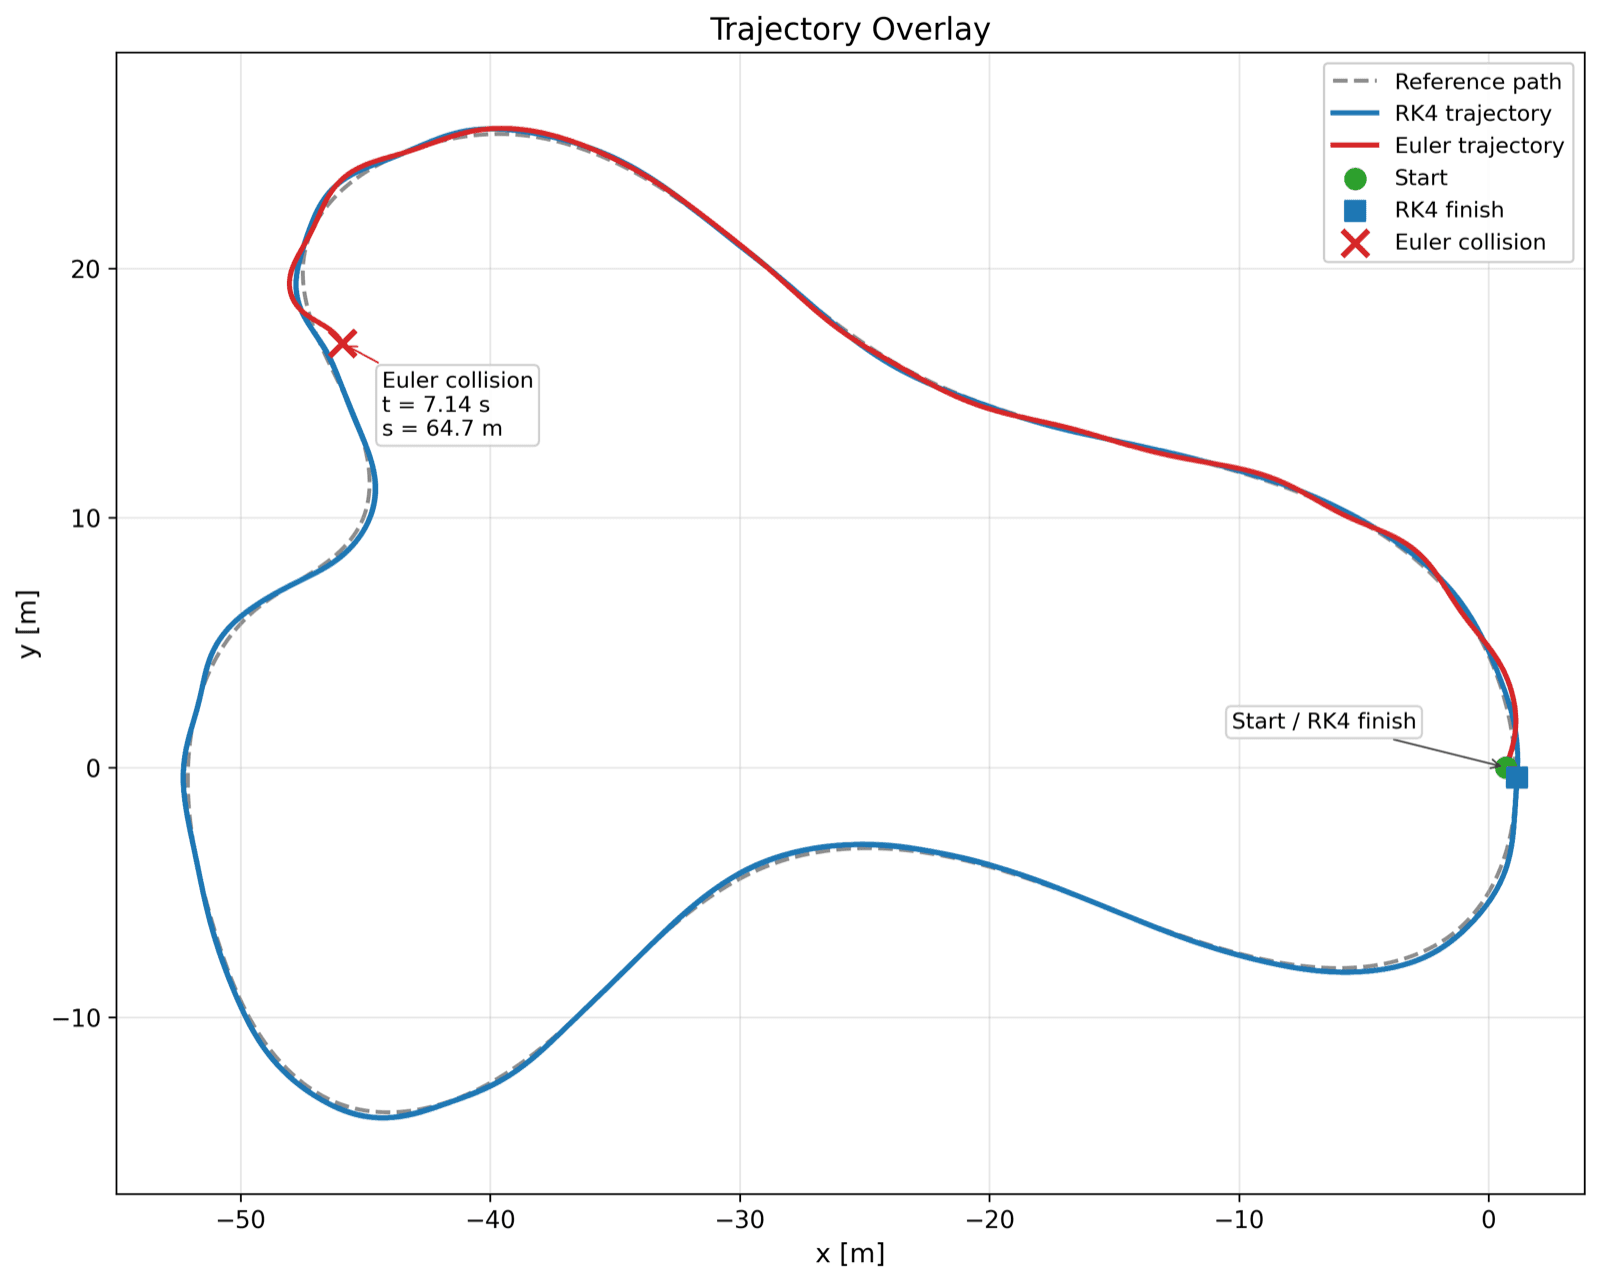
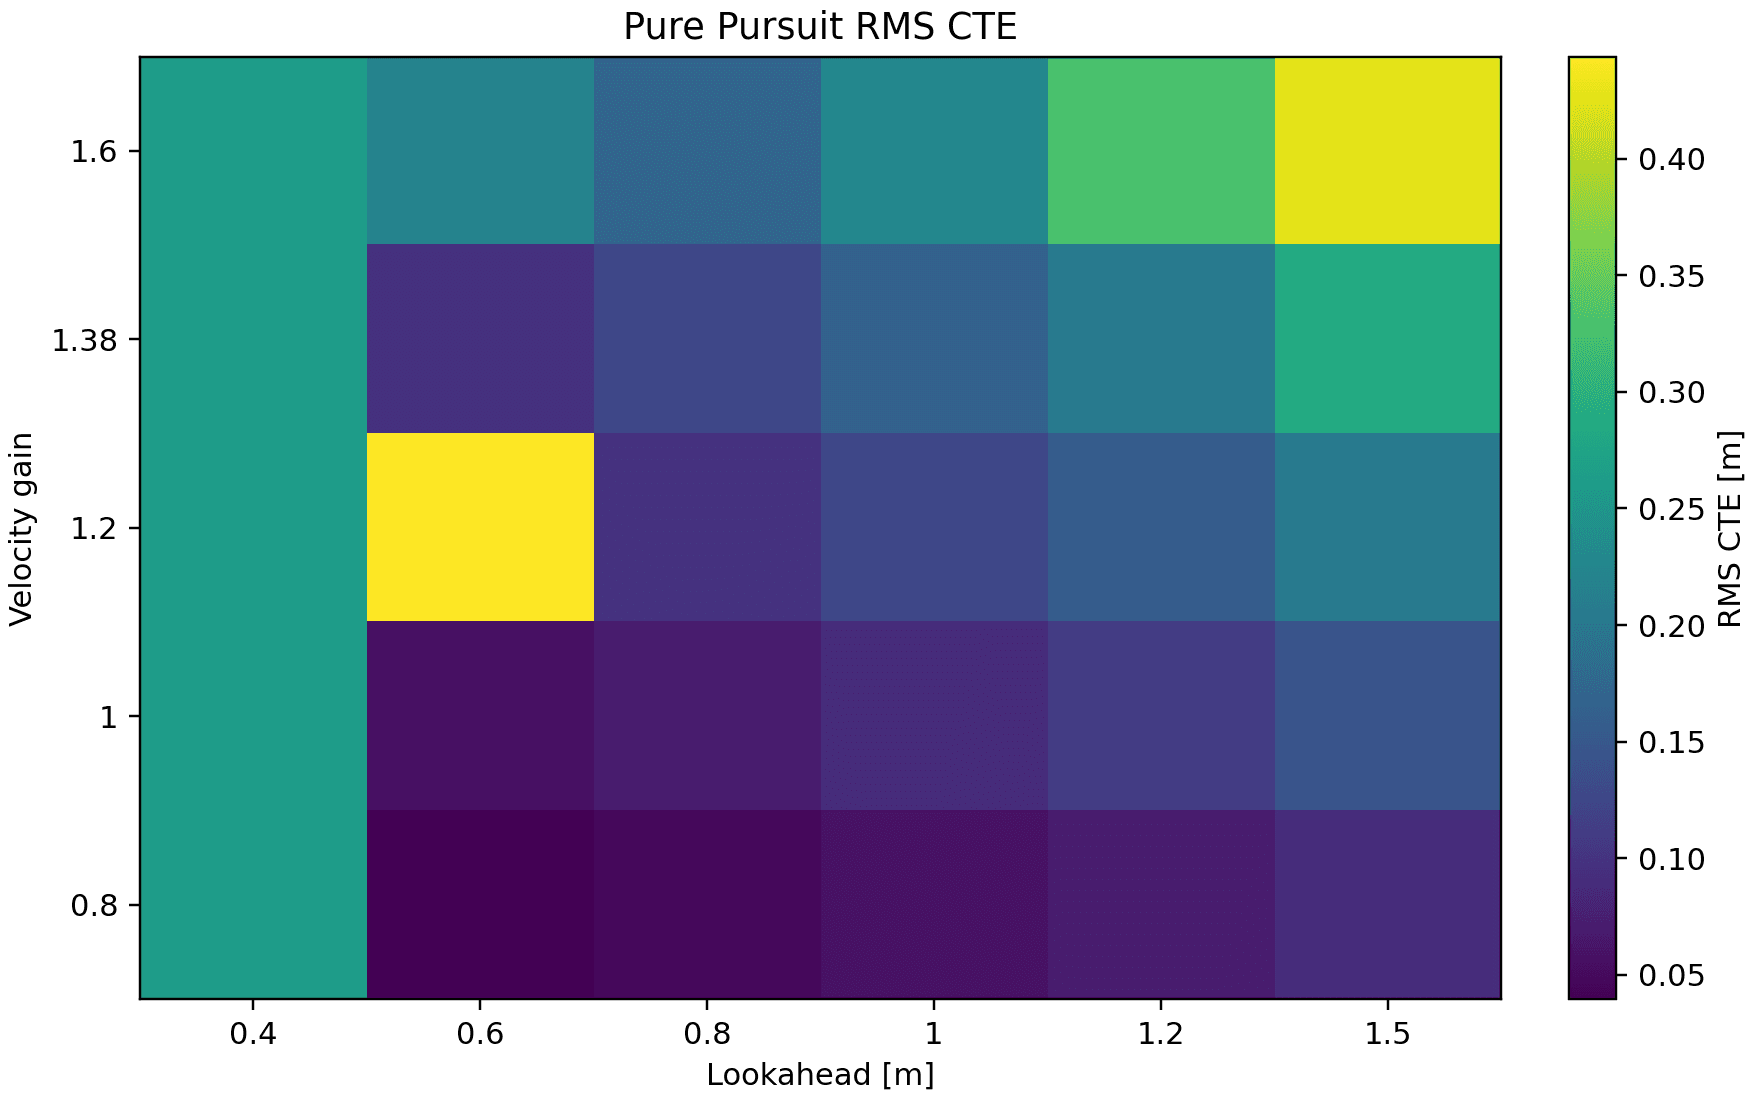
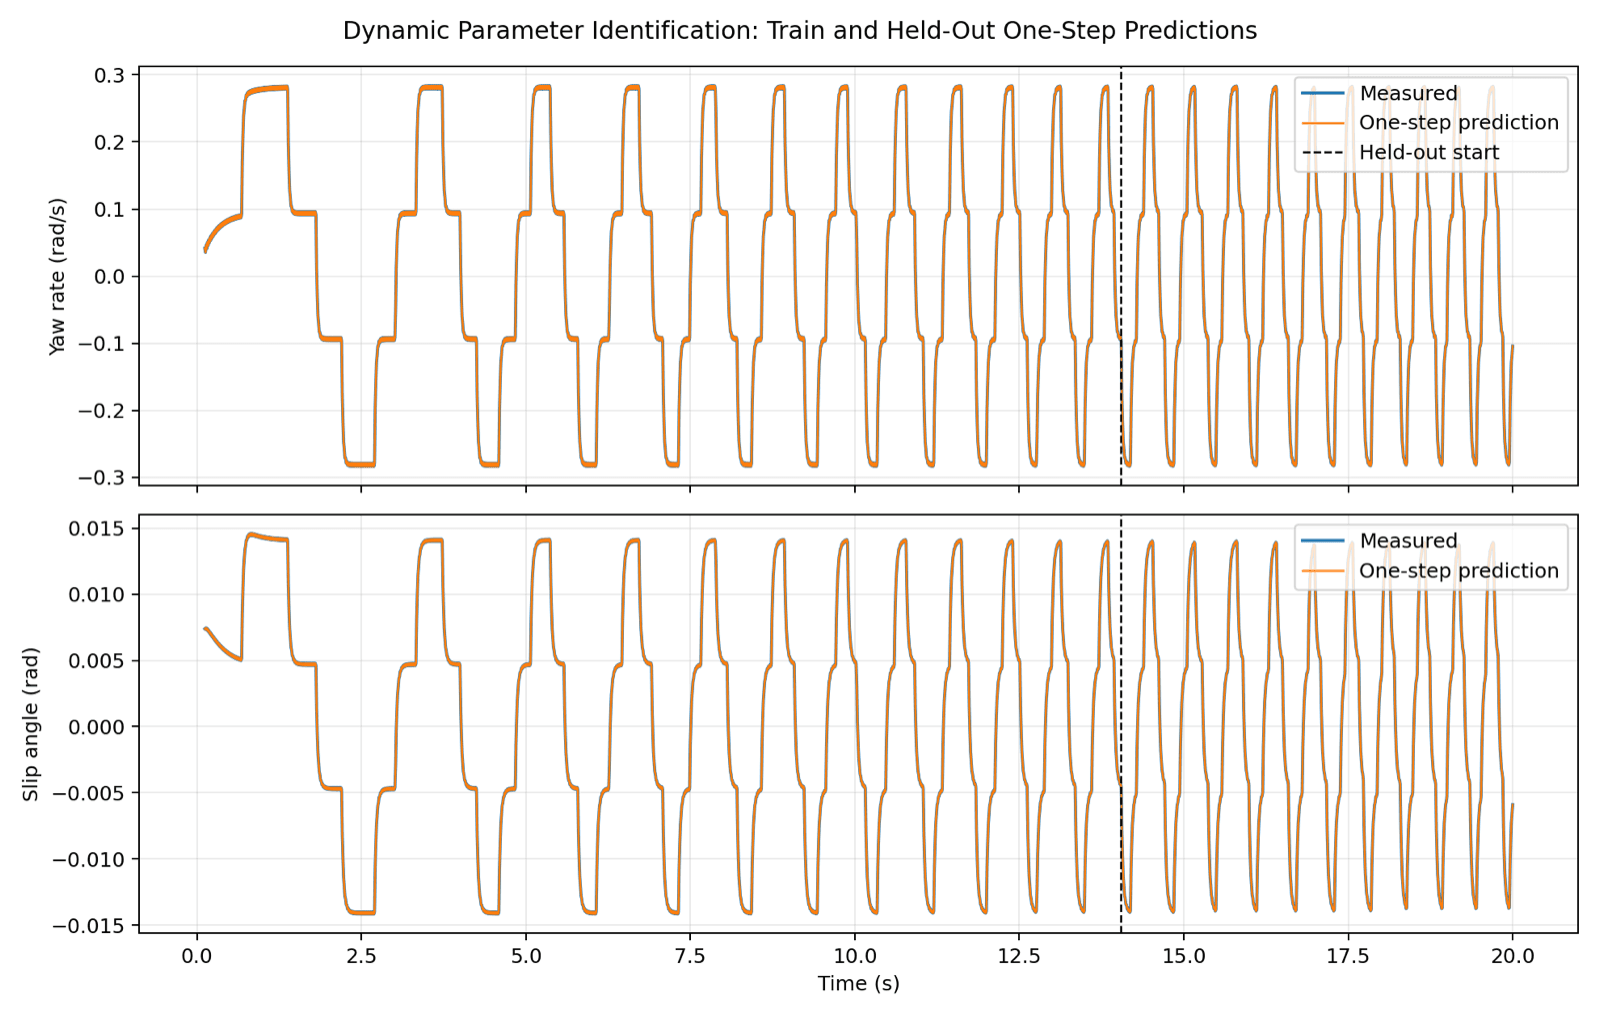
The project combines vehicle identification on telemetry generated by the fitted simulator model with controls and LiDAR-mast design. Held-out replay checks implementation consistency. The mounting review starts with a low rigid mount; the final height and any deck-mount close-out remain undecided. The prepared static-compliance test cannot establish vibration clearance.
| Category | Robotics |
|---|---|
| Timeline | 2025 - Present |
| Status | In Progress |
| Evidence | Converged FEA; physical test pending |
| Role | Modeling, system identification, controller evaluation, mechanical analysis, FEA convergence, and physical-test design |
| Tools | Python, ROS 2, CalculiX, Gmsh |
| Materials | 6061-T6 aluminum tube, printed/machined mast fixture |
| Links | RepositoryPhysical Protocol |
problem
My contribution. Built the experiment-to-report pipeline, controller comparisons, mast hand calculations, static/modal FEA, convergence checks, tolerance stack, and preregistered compliance analyzer.
A fast RoboRacer needs defensible vehicle models and a LiDAR structure that does not corrupt the scan plane. The design had to catch failures before fabrication and connect every result to a reproducible run.
constraints
- The former 200 Hz criterion does not establish vibration clearance; its basis needs review.
- The analyzed tube is 100 mm long, with 20 mm OD and 1.5 mm wall; its suitability remains unresolved.
- Physical compliance needs a 0.001 mm indicator at the planned 20 N load.
- Deflection validates compliance, not stress without strain instrumentation.
design evolution
Iterations, issues, and fixes, recorded in the order they happened.
| Revision | Failure mode | Design change | Result |
|---|---|---|---|
| Baseline analysis | The hand calculation for the 120 mm × 16 mm mast predicted 174.7 Hz. | Shortened the mast and increased the tube diameter. | The redesigned hand model reached 330.1 Hz. |
| FEA convergence | A single mesh could make agreement look better than it is. | Ran three refinements and used gauge-region/global metrics instead of singular peak stress. | Final changes stayed below 1.5%; FEA f1 = 285.5 Hz. |
| Physical gate | A standard 0.01 mm indicator provides only about three counts at 20 N. | Registered a 0.001 mm instrument, fixture subtraction, two axes, five loads, and three cycles. | Executable verdict is ready; measurement remains pending. |
results
Attaching the tip mass to one wall node caused most of the 13.5% gap to the hand model; a coupled, centred mass sits 2.8% away. 285.5 Hz stands until the new model is re-converged.
VALIDATED requires R² ≥0.99, hysteresis ≤5%, relative U95 ≤10%, and measured as-built compliance within ±15% of as-built FEA.
Scope note. The mast has not yet been fabricated or physically tested. Current structural results are hand calculation and FEA, not measured validation.
lessons
- A converged model can satisfy a numerical threshold while the threshold itself fails to establish the intended performance.
- Convergence and region selection matter more than a visually dramatic peak-stress contour.
- Instrument resolution should be screened against the actual planned load, not the original high-load model point.
gallery